Jingsong (Jason) Liang
Ph.D. Student at Nanyang Technological University

Jingsong Liang is a PhD student in Robotics and AI at Nanyang Technological University, supervised by Prof. Chen Lv and Prof. Wanhua Li. He is a recipient of the IGP Artificial Intelligence-X Scholarship.
His research centers on Multimodal Embodied Generalist Agents (MEGA), aiming to build general-purpose agents that integrate multimodal perception, embodied reasoning, autonomous planning, and continual self-improvement in the physical world. He also works closely with Sharpa on visual-tactile manipulation.
News 🎉
| Aug 10, 2026 | Our paper on human-vehicle interactive world model has been accepted by STEAI at ECCV 2026! |
|---|---|
| Aug 04, 2026 | Organizing committee of the EIR 2026. |
| May 22, 2026 | Best Poster Award at SRISS 2026 🏆 |
| May 05, 2026 | Our paper on cooperative multi-agent navigation (ORION) has been accepted by RA-L! |
| Jan 31, 2026 | Our paper GRATE has been accepted by ICRA 2026! |
| Dec 05, 2025 | Invited speaker at IEEE MRS 2025! |
| Nov 06, 2025 | Happy to receive the prestigious IGP-AI-X Research Award! 🎉 |
| Oct 20, 2025 | Best paper award at Active Perception Workshop, IROS 2025 ! 🏆 |
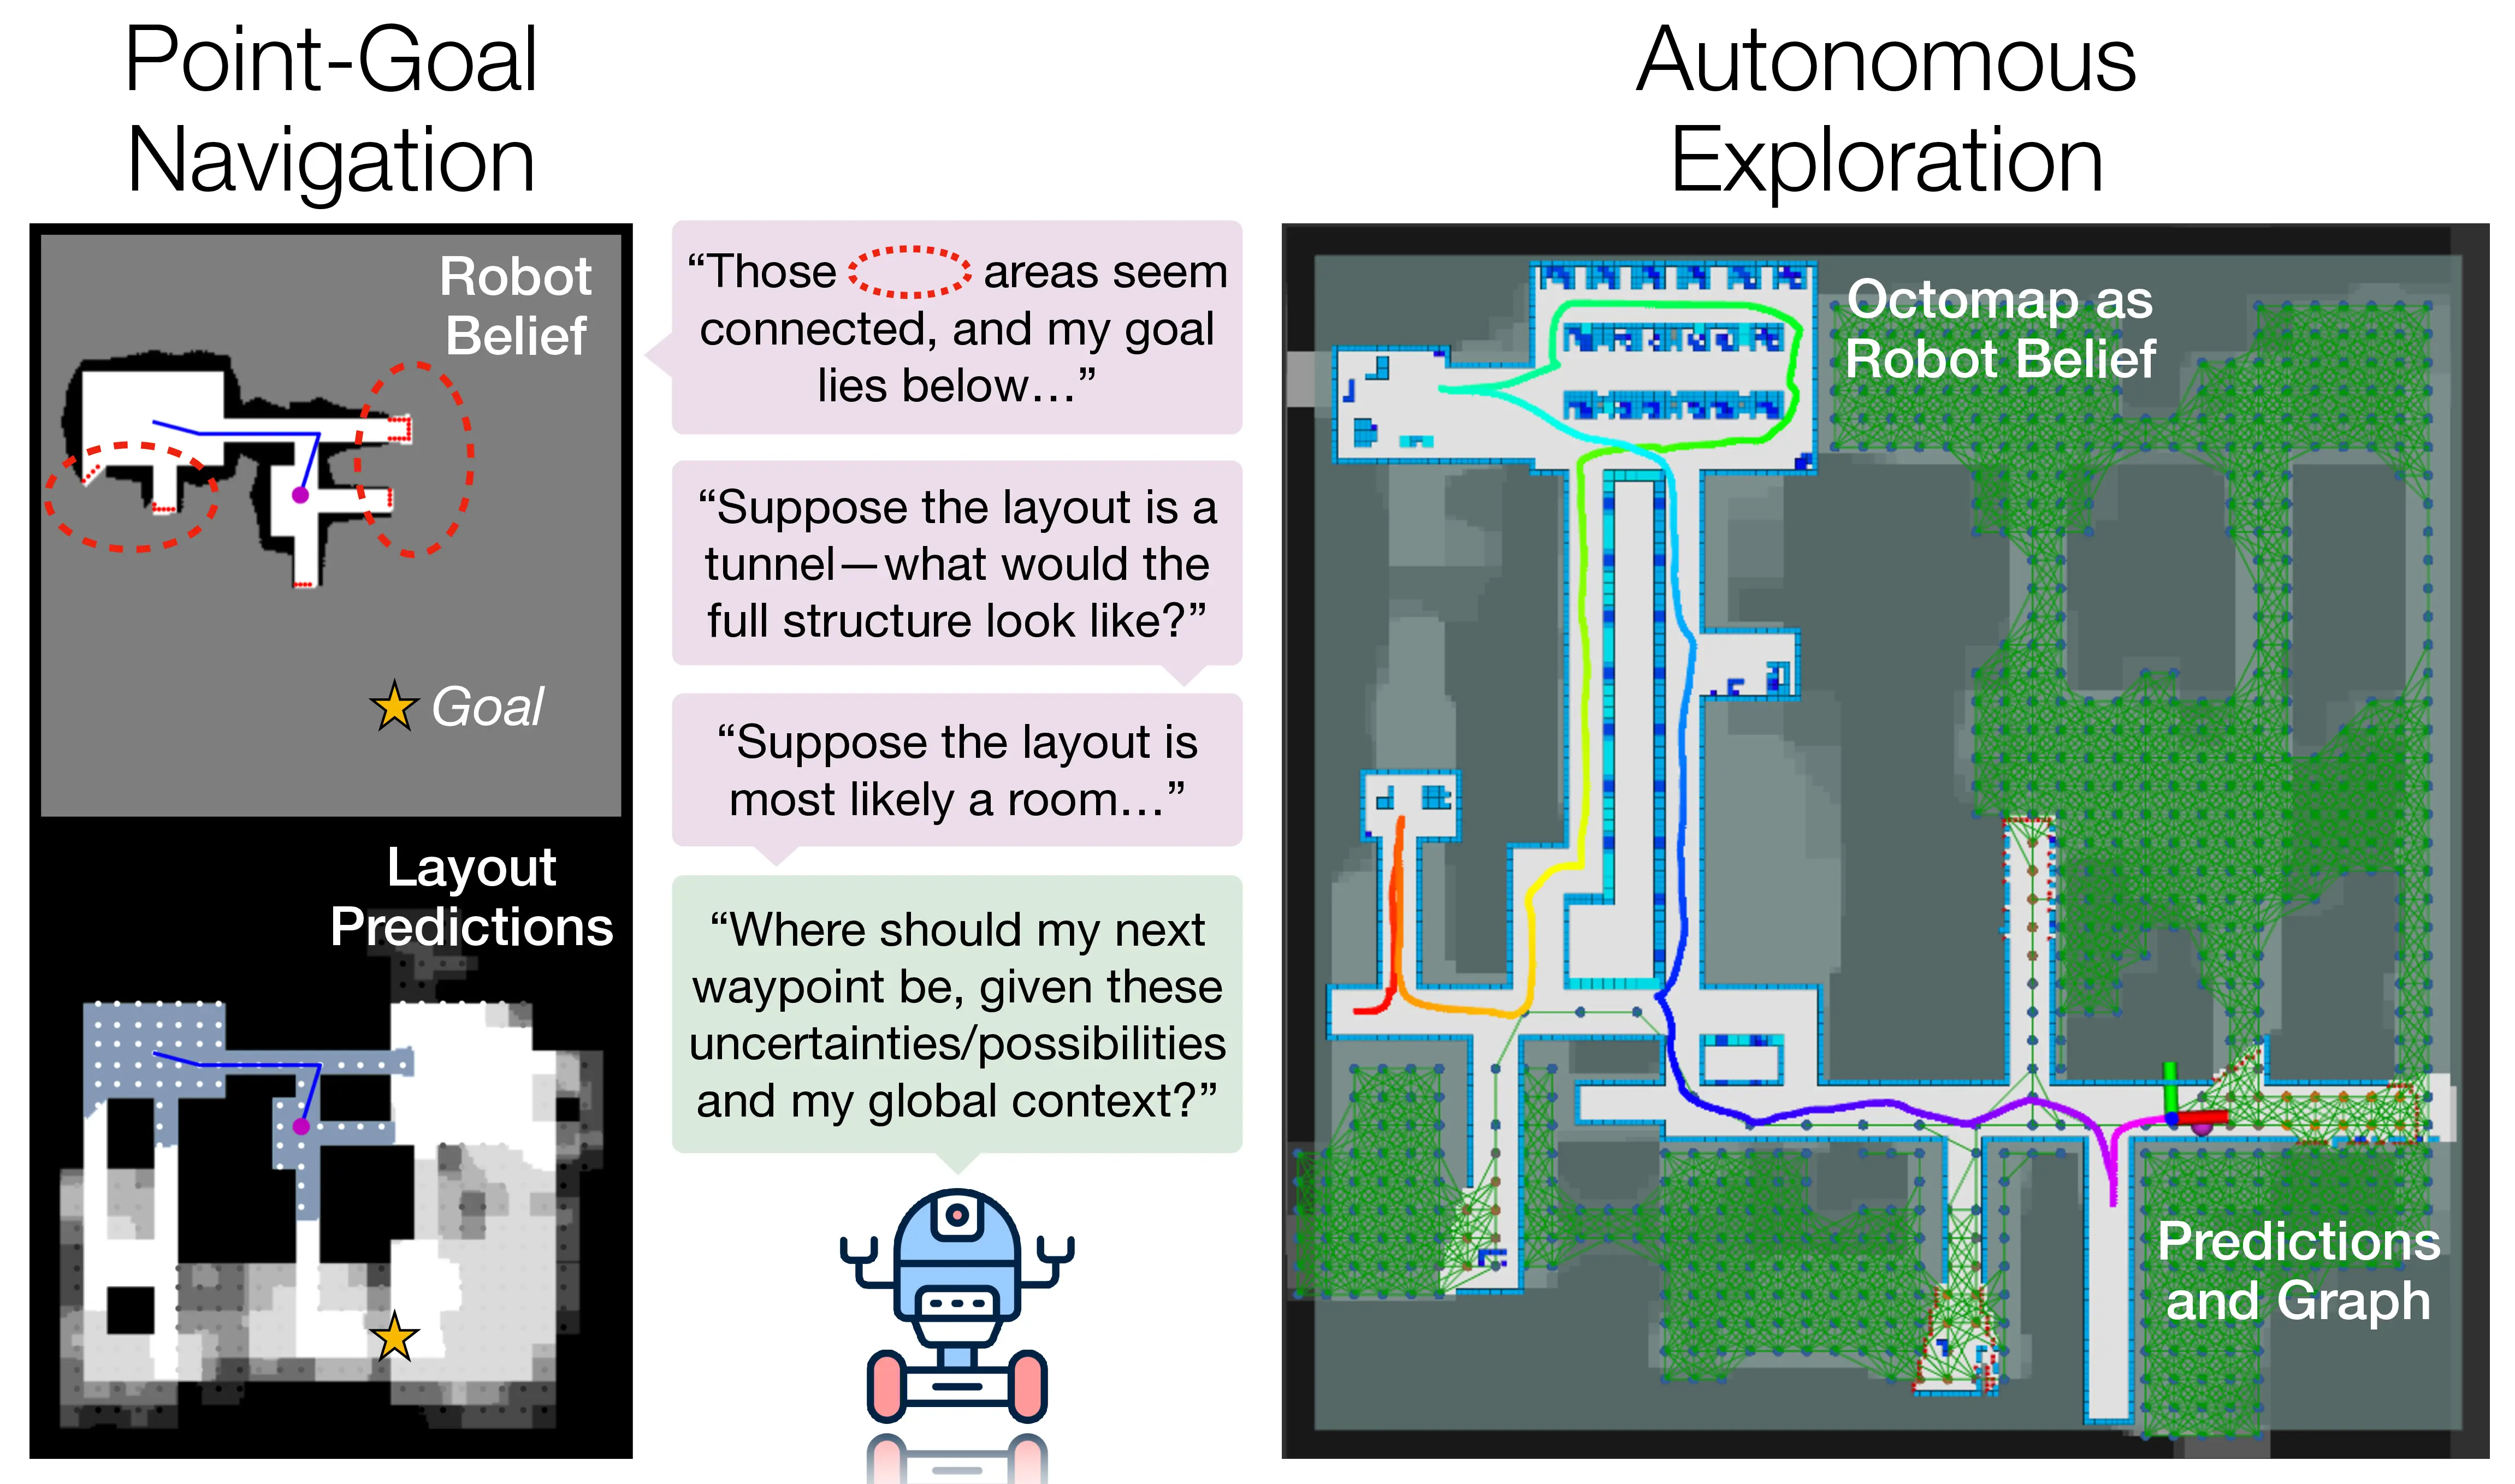
| Aug 02, 2025 | Two papers on (1) inpainting-aware exploration and navigation (CogniPlan) and (2) multimodal GTSP have been accepted by CoRL 2025! See you in Seoul, Korea! |
| Jan 28, 2025 | Our paper on diffusion-based exploration (DARE) has been accepted by ICRA 2025! See you in Atlanta, USA! |
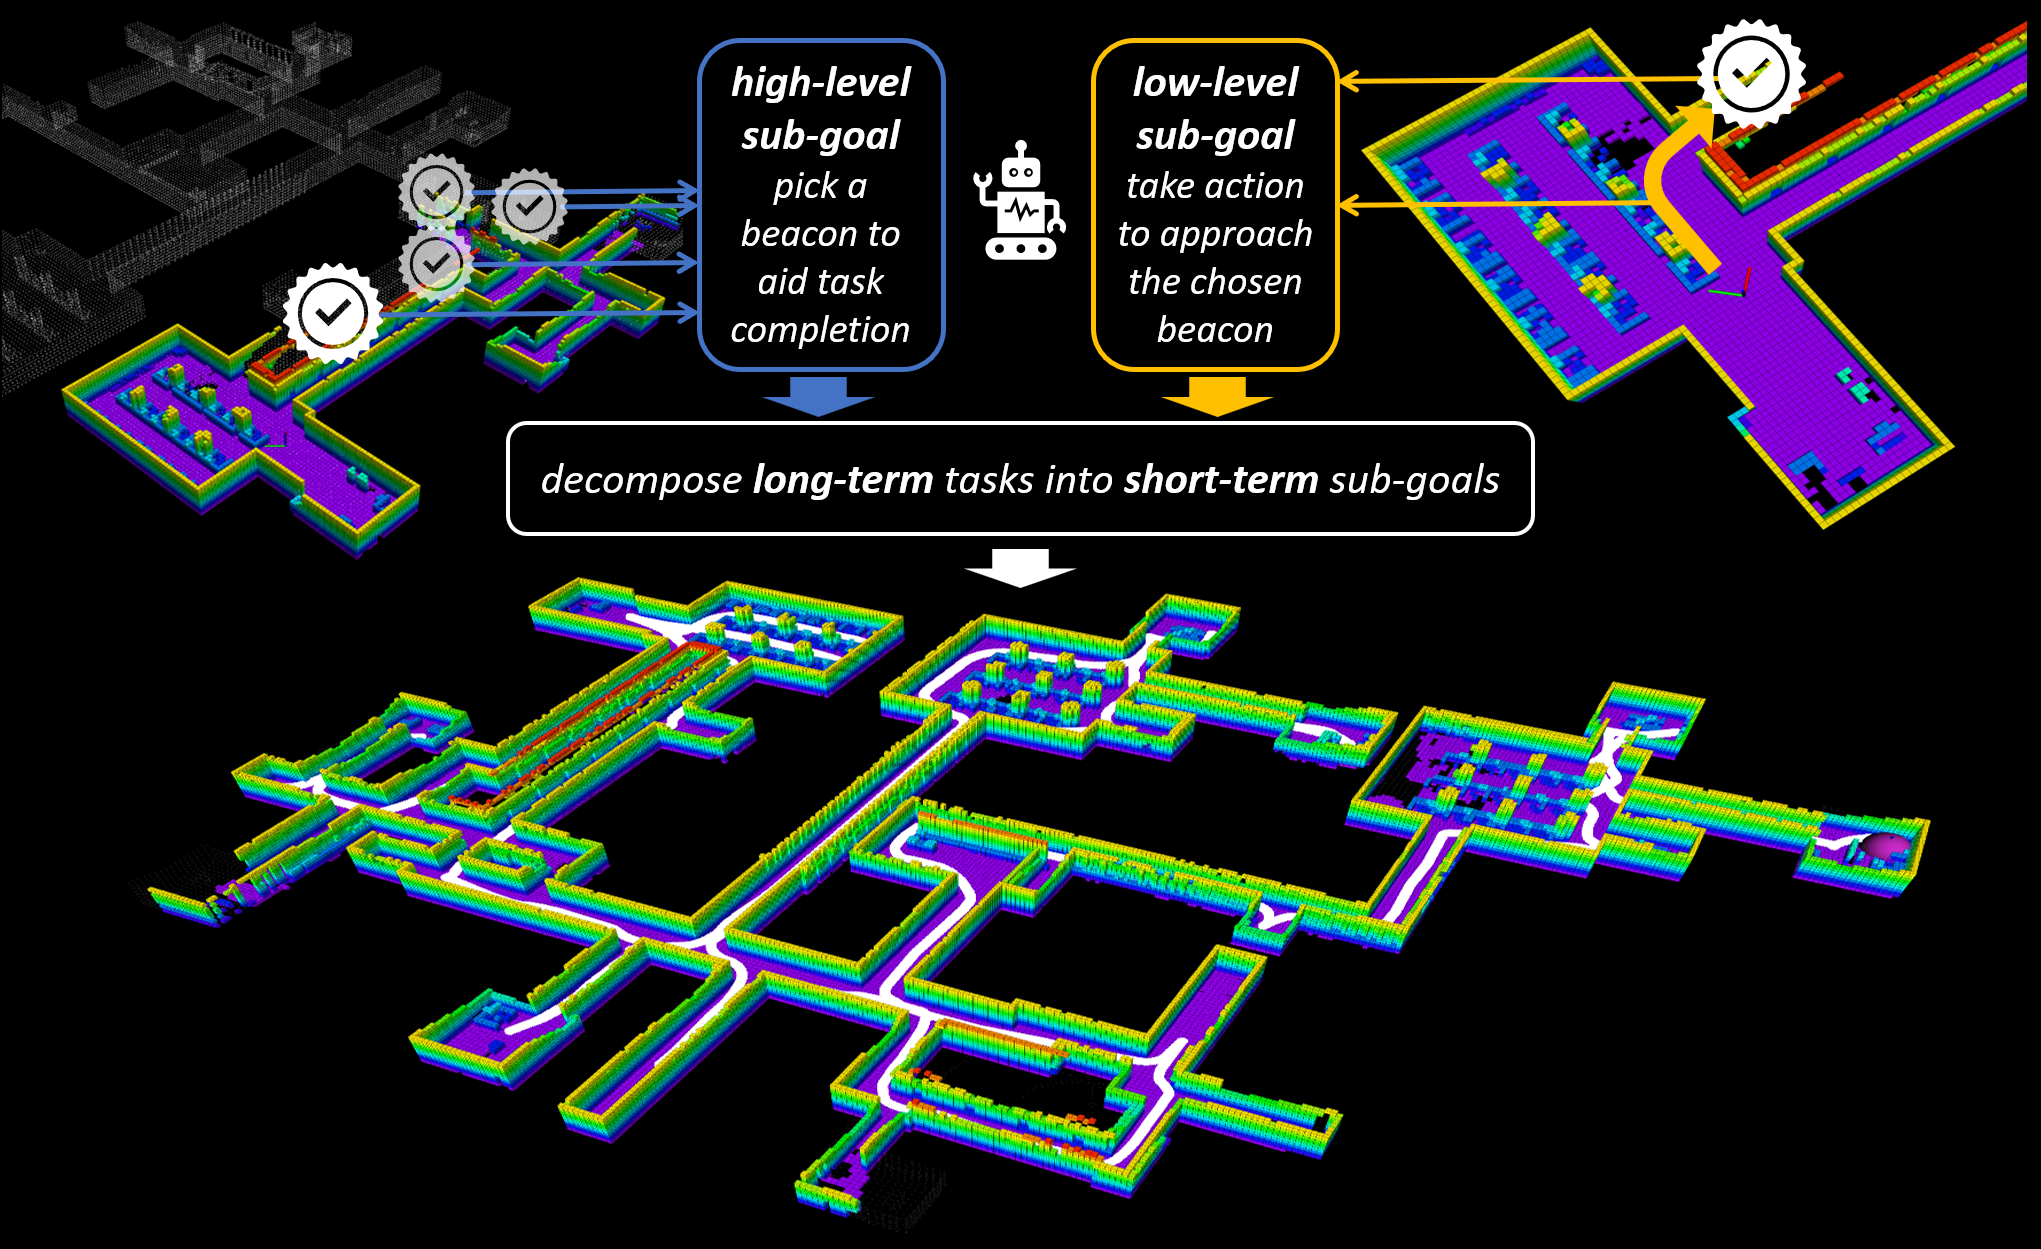
| Nov 05, 2024 | Our paper on hierarchical planning for navigation and exploration (HDPlanner) has been accepted by RA-L! |
| Jul 01, 2024 | Our paper on information sharing for multi-robot exploration has been accepted for oral presentation by DARS 2024! |
| Jun 30, 2024 | Our paper on multi-robot exploration and rendezvous under limited communication range (IR2) has been accepted for oral presentation by IROS 2024! |
| Apr 22, 2024 | Invited talk on “hierarchical planning for multi-agent systems.” Thanks to Prof. Guillaume Sartoretti and Prof. Harold Soh for hosting 🎉 |
| Aug 31, 2023 | Our paper on mapless navigation has been accepted by CoRL 2023! See you in Atlanta, USA! |
Selected Publications 🎉
-
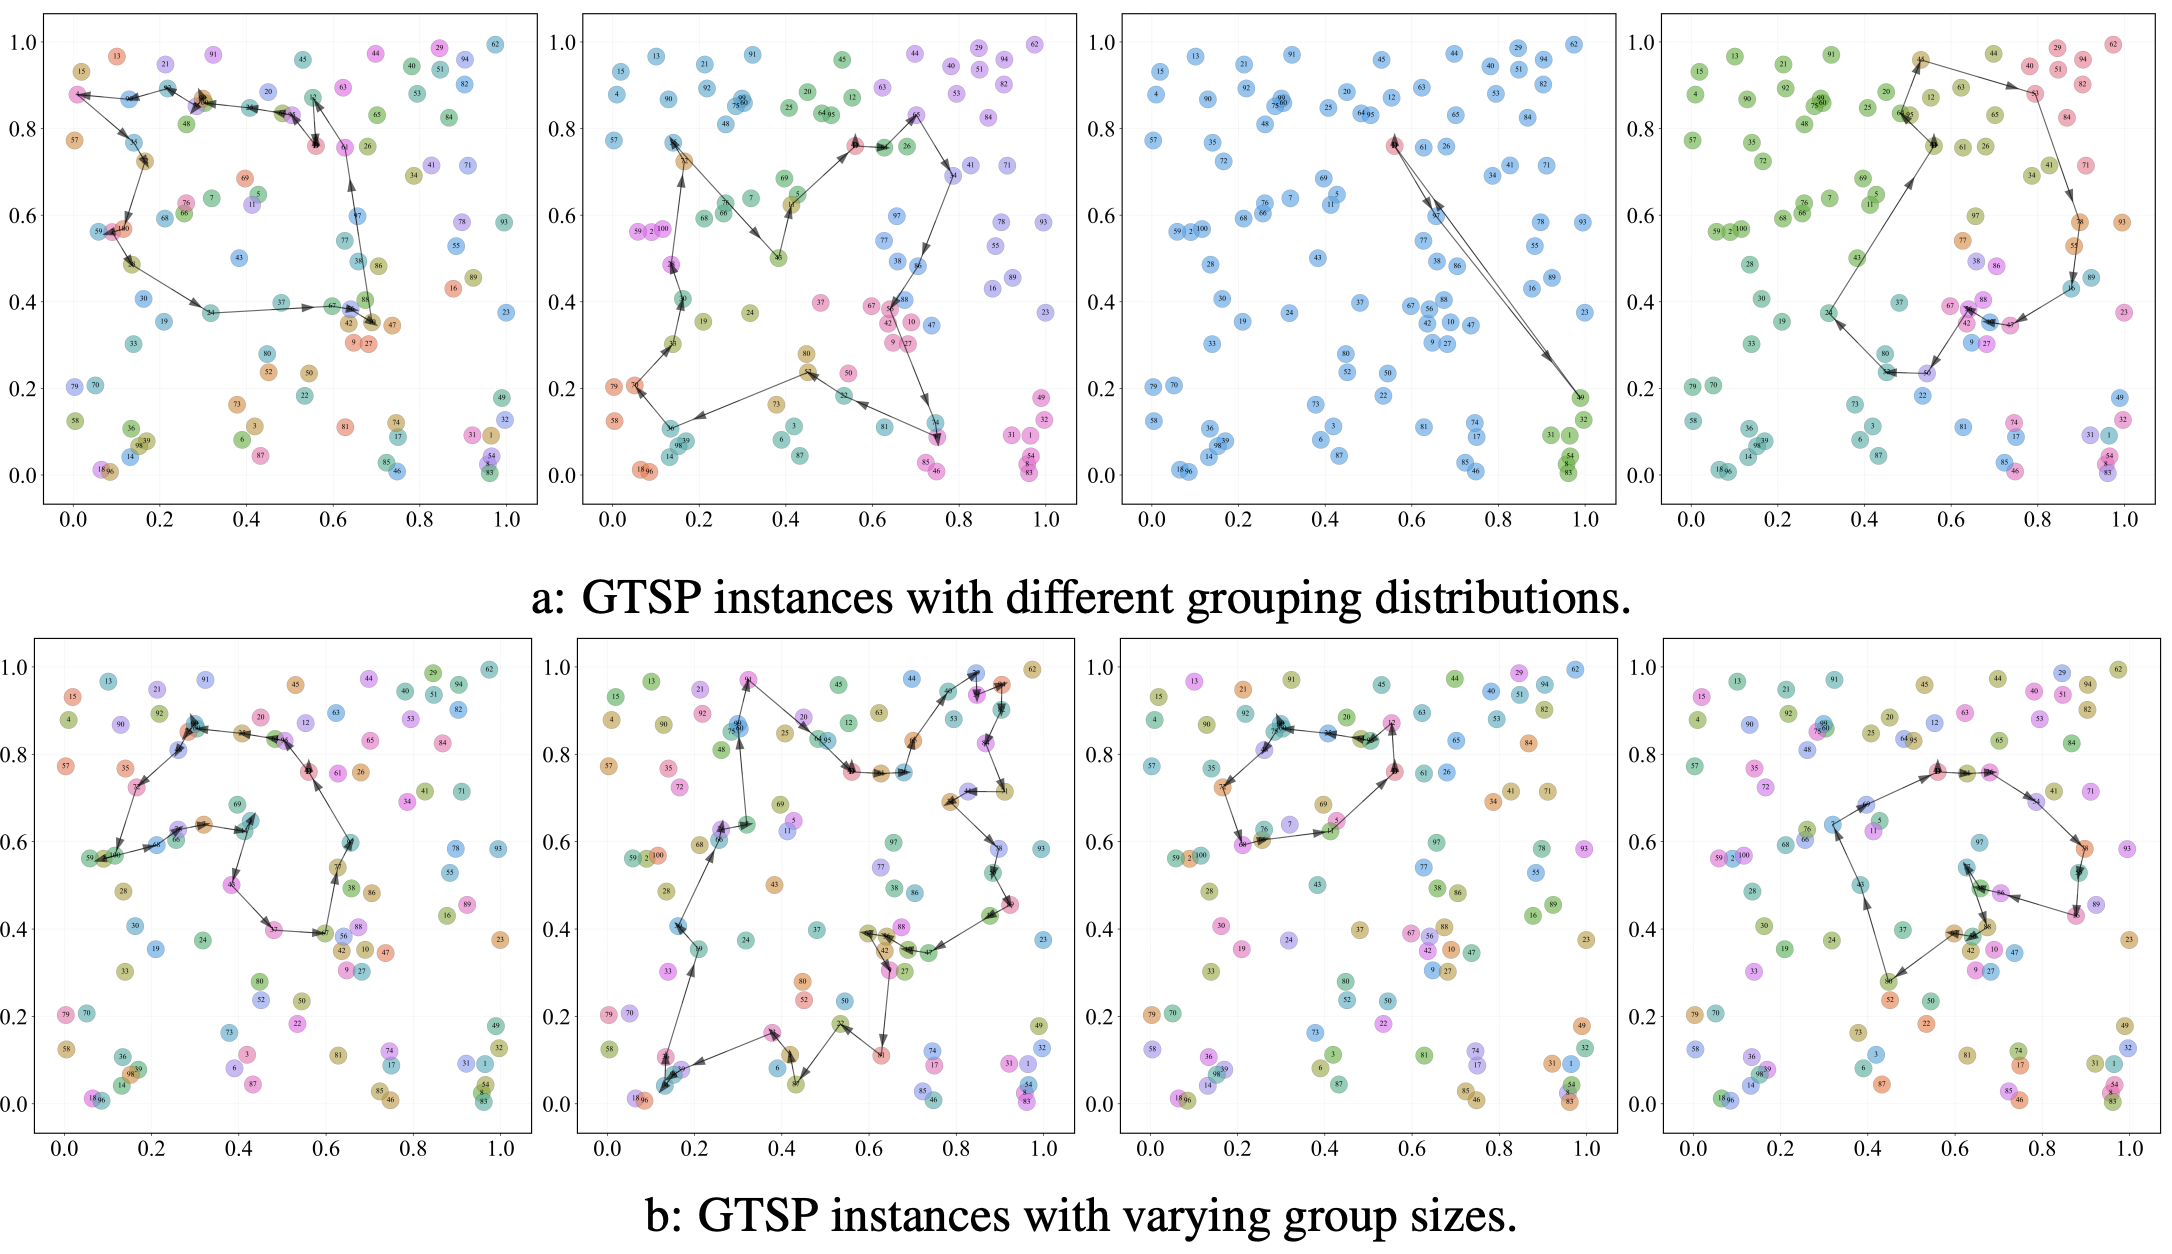 Multimodal Fused Learning for Solving the Generalized Traveling Salesman Problem in Robotic Task PlanningConference on Robot Learning (CoRL), 2025






Community Service
- Conference Reviewer: ICLR, NeurIPS, ICRA, IROS, ECCV, AAAI.
- Journal Reviewer: RA-L, T-ASE.
- Workshop Reviewer: CL4FMAgents@ICLR2027, DexHAND@ECCV2026.